
MA Reflex / The adaptive runtime for robots
Show it once. It does the job.
MA Reflex gives a machine one-shot learning, lasting memory and a safety gate on every action, on top of the policy it already runs. On a CPU, at the edge, offline.
1
Demonstration per job
270 / 270
Placements on a new robot, in simulation
1.68 ms
Per gated action, on a CPU
01 / Why a runtime
Why robots need a runtime.
A robot is expensive to teach. A new task means data collection, training time and an integration project. A new machine means doing much of it again. MA Reflex removes most of that loop, and it keeps working when the scene changes.
Your hardware, sensors, perception and models stay as they are. MA Reflex is the runtime layer on top of them.

02 / Every machine that moves
MA Reflex is coming to every machine that moves.
One runtime, on top of the policy or controller the machine already runs.
- 01
Industrial robots
Cells, lines and changeovers.
- 02
Mobile robots
Warehouses and yards where the layout changes every night.
- 03
Commercial and service robots
Cleaning, retail, hospital and delivery robots that meet a new floor every shift.
- 04
Uncrewed combat aircraft
Machines that must hold their rules at the edge.
- 05
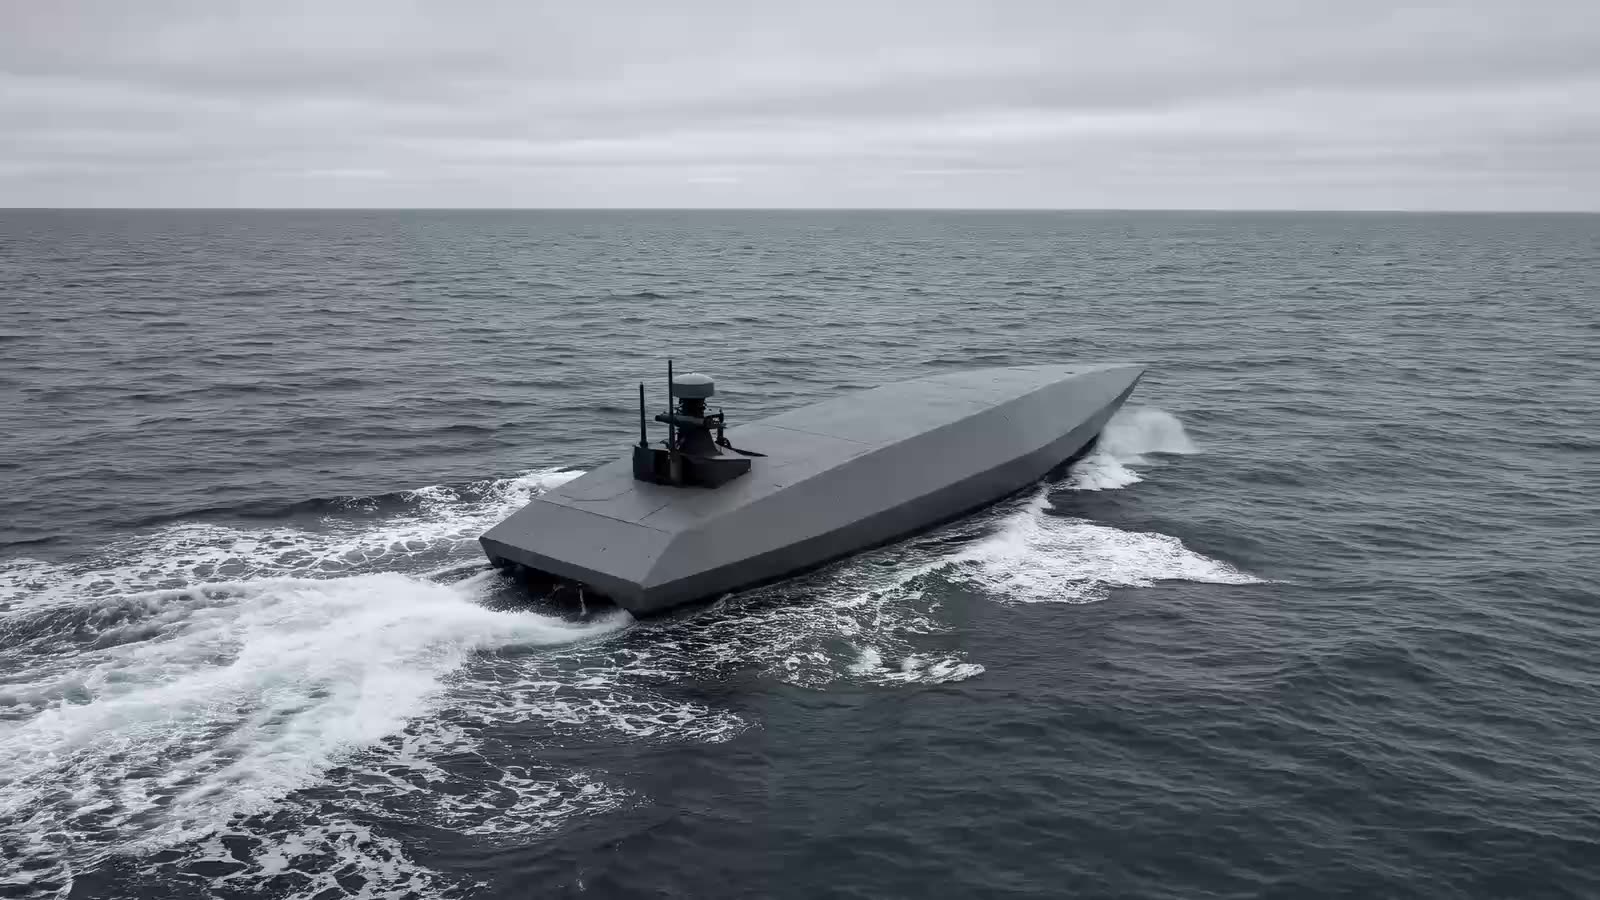
Ground and maritime vehicles
Machines working far from a network.
- 06
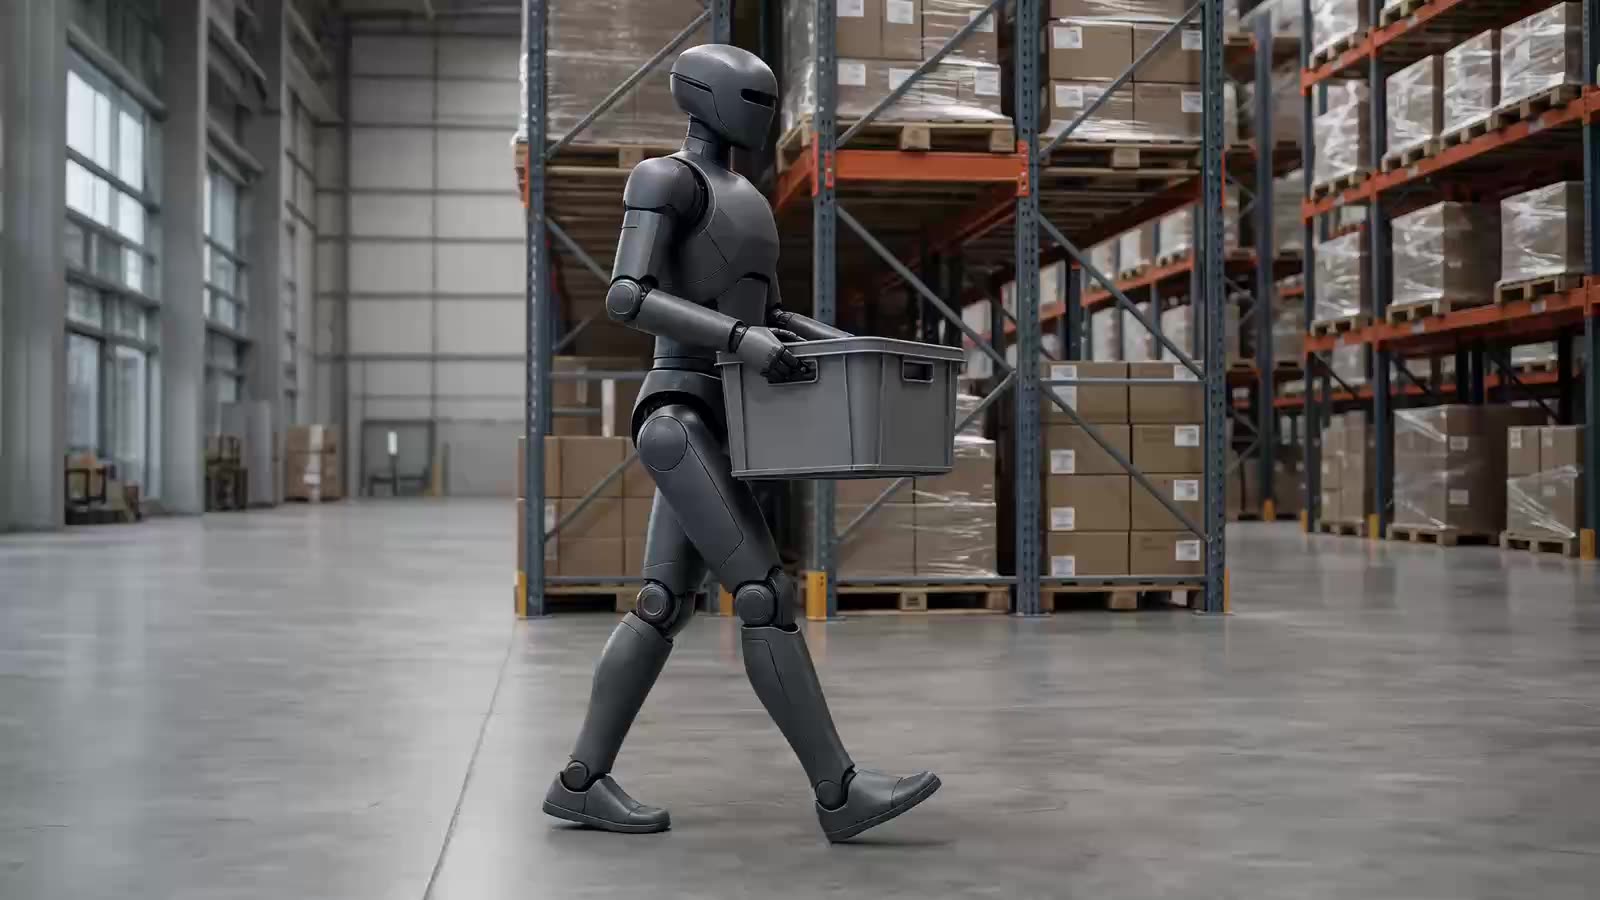
General-purpose humanoids
Humanoids on factory and warehouse floors. On our roadmap; the work so far is in simulation.


03 / Day one
What changes on day one.

- 01
It sets itself up.
Connect the machine and MA Reflex works out its own body. In simulation, on simulated models of three commercial arms, that took under five minutes.
- 02
The job is shown once.
Where the tool goes, when the gripper closes, where things sit. One demonstration. Nothing is trained.
- 03
Every action is gated.
From the first move, confident actions commit, uncertain ones defer and unsafe ones are refused.
- 04
Every action is on record.
Each lesson and each action lands in a signed, tamper-evident record.
04 / From plug-in to production
From plug-in to production.
01
Plug in
MA Reflex works out the machine's own body.
02
Show once
Demonstrate the job a single time. Nothing is trained.
03
Practice
It rehearses where it was shown, accounts for every phase and finds the grasp that holds.
04
Run
It does the job at new layouts and on other robots, with every action passing the safety gate.
05 / Self-setup
A robot nobody described sets itself up.
No description file to write, no calibration day. Measured in simulation, on simulated models of three commercial arms, it took 193 to 296 seconds, inside a five-minute budget.

06 / One-shot learning
One demonstration. Any layout. Another robot.
In simulation, a job shown once on one robot was carried out by a different robot at 30 new layouts. 270 of 270 placed, zero retries, median placement error 0.57 to 2.45 mm. With noise added to the camera frames, still 270 of 270.

270 / 270
Placed on another robot, in simulation
0
Retries
0.57–2.45 mm
Median placement error
07 / Beside your policy
Makes great policies better.
MA Reflex shares the job with your policy phase by phase. Across forty tasks on a simulation benchmark, success with objects moved rose from 66% to 79%, and from 39% to 65% with the object 21 cm away. The policy was asked 13.4 times per episode instead of 32.8.

79%
Success with objects moved, from 66%
65%
With the object 21 cm away, from 39%
13.4
Policy calls per episode, from 32.8
Forty tasks on a simulation benchmark.
08 / Safety gate
Commit. Defer. Refuse.
Every action passes a gate. Confident actions commit. Uncertain ones defer to the policy or the operator. Unsafe ones are refused or held inside the keep-out zones you set, and the system fails closed. A corrupted sensor reading is refused, not acted on. Limits can be added or released at runtime.

09 / Lasting memory
Skills that never overwrite each other.
Teaching the tenth skill leaves the first nine exactly as they were. MA Reflex recalls the right skill from context, combines known skills for new goals and chains them into monitored multi-step jobs. It remembers places and what worked there. Remove a skill and nothing else moves.
10 / Edge native
Runs on a CPU. Offline. Air-gapped.
No GPU, no cloud dependency, no data leaving the site. A gated action takes 1.68 ms and the loop clears 20 Hz on a CPU. Every lesson and every action lands in a signed, tamper-evident record, and field experience can be exported as a signed training set.
1.68 ms
Per gated action, on a CPU
20 Hz
Control loop cleared, on a CPU
11 / Autonomous skill acquisition
A new skill, acquired on its own.
With no policy, no demonstration and no reward, MA Reflex can acquire a new skill on its own, safely under the gate, and keep it.
12 / For operators
What operators get.

- 01
Teach by showing.
Show the job once. Nothing is trained, and the job carries to new layouts.
- 02
Limits they control.
Keep-out zones and limits added or released while the machine works, and held on every action.
- 03
A clear answer on every action.
Commit, defer or refuse. When it defers, the decision comes to them.
- 04
A record they can check.
Every lesson and every action, signed and tamper-evident, verifiable while it runs.
13 / For engineers
What engineers get.

- 01
Connectors for the stacks you run.
Hugging Face LeRobot, SO-101, NVIDIA Isaac, ROS 2 and MoveIt 2, and on-device vision.
- 02
A certification battery.
Know before deployment whether an adapter passes.
- 03
A Python SDK and HTTP API.
Every capability, from teaching a skill to reading the record.
- 04
A signed training set.
Field experience exported to make the base policy stronger.
14 / Where it runs
On the machine. Not in somebody's cloud.
MA Reflex runs on the machine or on an edge computer beside it, on a CPU. It needs no network, so it works offline and air-gapped, and nothing leaves the site unless you send it.
- On the machine or an edge computer beside it
- CPU only, no GPU
- Offline and air-gapped
- A single edge node or a whole fleet
- On your premises

15 / What it costs to run
No GPU to buy. No training run to pay for.
MA Reflex runs on the CPU a machine already carries. A new job takes one demonstration, not a training run. And every call it takes off the policy is compute you no longer spend.

0
GPUs required
0
Training runs for a new job
2.4×
Fewer policy calls, on a simulation benchmark
1.68 ms
Per gated action, on a CPU
16 / How a pilot runs
How a pilot runs.

01
Start in simulation
The whole loop runs on a laptop, with no hardware and no cloud.
02
One machine, one job
On your floor. MA Reflex sets the machine up and is shown the job once.
03
Measure it
Success, policy calls and every gated action, all on record.
04
Roll it out
For your machines, your lines or your fleet.
17 / Proof
One demonstration, measured across robots and tasks.
Measured in simulation, on simulated models of commercial arms and on a forty-task simulation benchmark.
| No. | Test | Result |
|---|---|---|
| 01 | A robot nobody described sets itself up | 193 to 296 s, inside a 300 s budget |
| 02 | A job shown once on one robot, done by another at 30 new layouts | 270 of 270 placed, 0 retries, 0.57 to 2.45 mm median error |
| 03 | Forty tasks, scenes as set | 96% with MA Reflex beside the policy, matching the policy at its best |
| 04 | The same tasks with the object or destination moved | 79% with MA Reflex, 66% for the policy alone |
| 05 | The same tasks with the object 21 cm away | 65% with MA Reflex, 39% for the policy alone |
| 06 | Calls to the policy per episode | 13.4 with MA Reflex, 32.8 for the policy alone |
| 07 | MA Reflex alone: no policy, no GPU, no training | 74%, 63% and 57% on the same three settings |
Measured in simulation. Rows 01 and 02 ran on simulated models of commercial robot arms. Rows 03 to 07 come from a simulation benchmark of forty tasks. Scene by scene, the shared job succeeded where the policy alone failed 129 times, against 46 the other way round.
Every result18 / Questions
Questions.
Does MA Reflex replace my policy?
No. It runs on top of it. MA Reflex takes the phases it knows and the policy keeps the rest.
What if we do not run a policy yet?
MA Reflex can be delivered together with a vision-language-action policy, integrated as one complete system. Open policies are supported through the Hugging Face LeRobot integration.
Ways to work with usDo I need a GPU?
No. It runs on a CPU, offline and air-gapped if you need it to.
Which machines does it work with?
Any machine it can read state from and command. MA Reflex is coming to every machine that moves.
Can we start before touching hardware?
Yes. The whole loop runs in simulation on a laptop, with no hardware and no cloud.
What happens when it is not sure?
It defers. The decision goes to your policy or to the operator, and the deferral is on record.
What if a sensor reading is wrong?
A corrupted or out-of-range reading is refused, not acted on, and the system fails closed.
How does it keep a robot safe?
Every action passes a gate that commits, defers or refuses, inside the keep-out zones you set, and the system fails closed. It runs alongside your hardware e-stop and safety controller.
Does it need a network?
No. It runs on the machine or beside it, offline, on a single edge node or across a fleet.
Can it learn with no policy at all?
Yes. It can acquire a skill on its own, exploring safely under the gate.
How do we get it?
Machine Autonomy offers MA Reflex to robot makers, integrators and operators, on its own or with a policy as one complete system. It starts with a pilot on one machine and one job.
Ways to work with us
Give your machines a reflex.
Bring one machine and one job. We will show it once and let MA Reflex take it from there.