Integrations
Beside the stack you already run.
Nothing to retrain. Nothing to replace.
01 / MA Reflex
For robots, with MA Reflex.
- Hugging Face LeRobot: ACT, Diffusion and VLA policies
- SO-101: in simulation or real
- NVIDIA Isaac: Isaac Lab and Isaac Sim policies
- ROS 2 and MoveIt 2: joint-state encoders and joint-command actuators
- On-device vision with no CUDA toolchain
- Python SDK and HTTP API

02 / Certification
Certify an adapter.
A certification battery tells you before deployment whether your adapter passes.
03 / MA Duplex
For AI agents, with MA Duplex.
- Any frontier model
- OpenAI and Anthropic compatible endpoints
- LangChain
- Python and TypeScript SDKs, a command line and an HTTP API
- Your memory, graph and tools

04 / Where it runs
Where it runs.
- 01
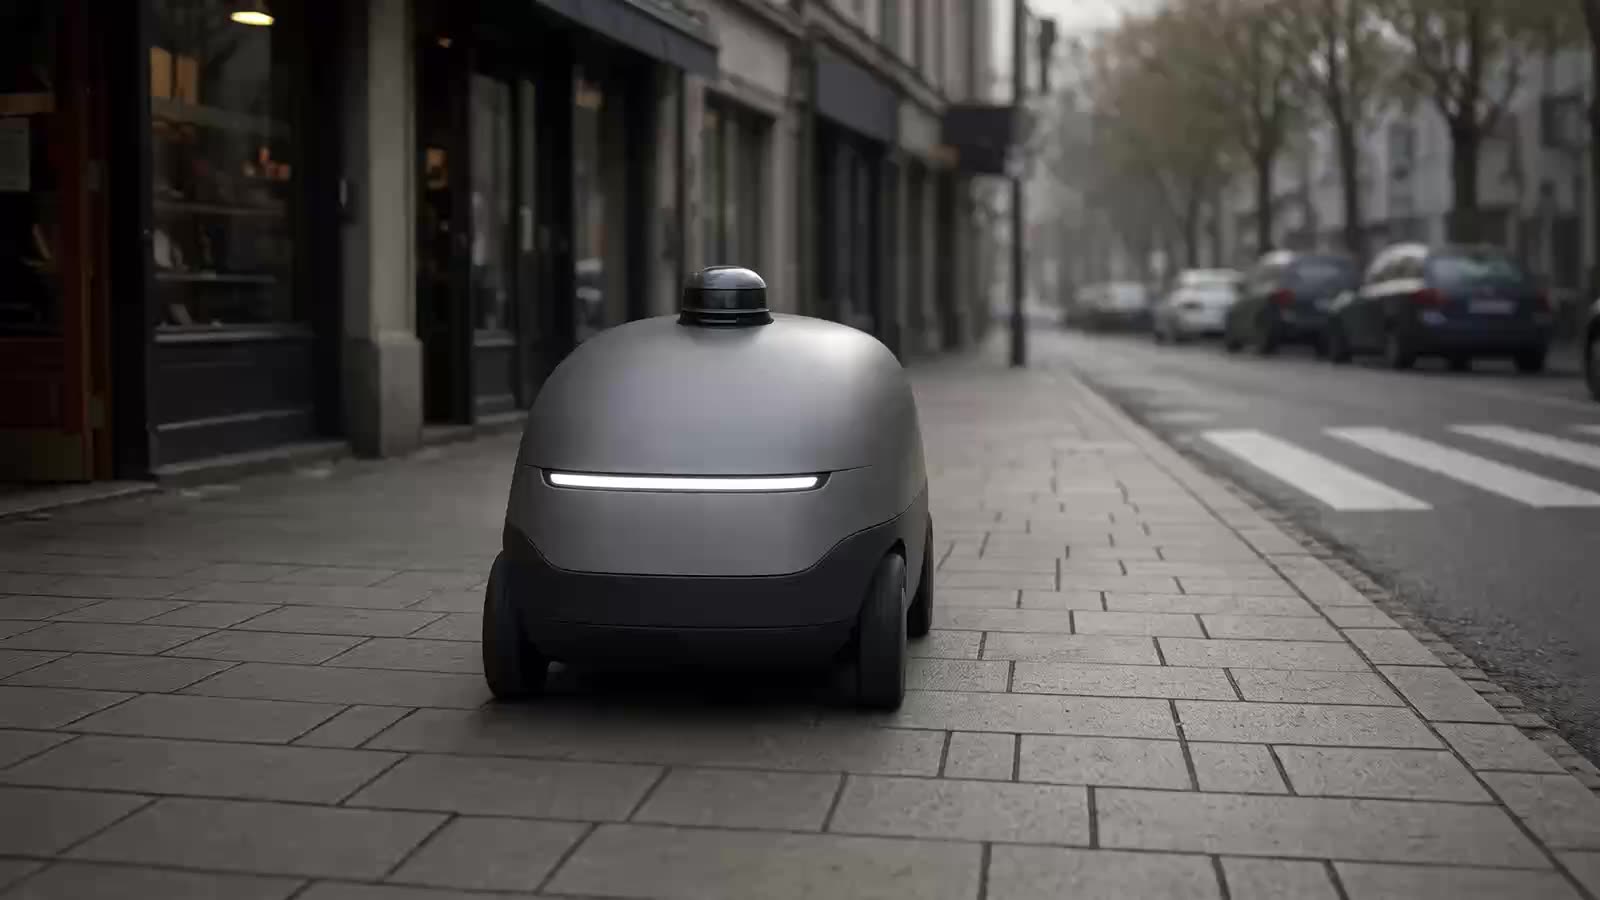
Robots
On a CPU, at the edge, offline.
- 02
Agents
In a separate environment managed for you, in your cloud account, on your premises or air-gapped.

